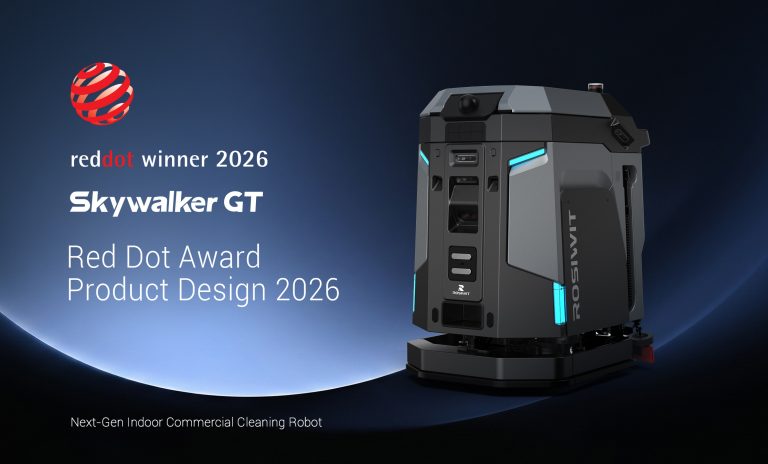
Comparative premise and operational context
The comparative insight approach examines how platform choices change measurable outcomes in industrial cleaning. Early in-field trials at logistics hubs such as the Port of Los Angeles highlighted differences in cycle time and consistency when switching from manual crews to autonomous solutions. A direct example is the deployment of an industrial cleaning robot that demonstrated reduced wet-dry transition time through integrated brush system controls and efficient autonomous navigation. This article compares architectures, quantifies performance gaps, and emphasizes observable operational impacts rather than marketing claims.
Hardware architectures: brushes, squeegees and power systems
Industrial platforms diverge primarily on mechanical subsystems. Single-disk brush heads provide concentrated scrubbing force but require higher torque motors; cylindrical brush arrays increase sweep width and debris handling at the cost of more frequent maintenance. The squeegee assembly design dictates water recovery efficiency and floor traction during water pickup. Battery management is not ancillary: cell chemistry, duty-cycle profiles, and on-board BMS algorithms determine available runtime and safe charge cycles. Selection should be treated as a clinical specification process—objectively measured torque, flow rate, and recovery percentage—rather than a subjective preference.
Sensing and control: SLAM, localization and payload trade-offs
Navigation stacks vary from simple waypoint-followers to full SLAM suites with multi-sensor fusion. SLAM improves repeatability in dynamic facilities but increases compute load and may require added payload for LiDAR or stereo cameras. Payload decisions influence center-of-gravity and turning radius, which directly affect coverage efficiency in tight aisles. Engineers must measure localization drift, obstacle-response latency, and the effect of added sensors on battery runtime to choose an appropriate control topology.
Operational teardown: integrating software, maintenance and benchmarks
In an operational production teardown, review teams should instrument cycle runs to capture three classes of telemetry: energy per square meter, mean time between service interventions, and effective coverage rate. During such a teardown engineers verified {main_keyword} integration and observed {variation_keyword} behavior within the path-planning module. Comparative logs showed that models with predictive maintenance flags reduced unplanned downtime by detectable margins. For practitioners considering alternatives, the industrial robotic floor scrubber form factor should be evaluated against maintenance intervals, spare-parts lead time, and service-level agreements established with vendors.
Common deployment errors and pragmatic alternatives
Deployment errors are typically procedural rather than technical. Frequent mistakes include underestimating floor-surface variability, skipping baseline floor-mapping, and failing to align charge schedules with shift patterns—errors that inflate downtime. Semi-autonomous tugs and ride-on scrubbers remain viable alternatives where full autonomy introduces unacceptable complexity. Preventive maintenance programs and clear SOPs for chemical dosing and brush replacement correct a large share of issues—small process changes with outsized returns. —A last-minute calibration check during the first week often resolves persistent localization anomalies.
Advisory: three critical metrics and selection rules
1) Energy efficiency per square meter: measure Wh/m² under representative loads; prefer systems that maintain ≥10% efficiency margin under peak demand.
2) Mean time to service (MTTS): require vendor data on MTTS and verify with on-site trials; target systems that exceed current manual MTBF by a measurable factor.
3) Coverage consistency: assess percent area cleaned per cycle and variance across repeated runs; choose platforms with <5% variance for tightly scheduled operations.
Prioritize measurable specifications and validated field data when comparing suppliers. Factor in spare-parts logistics and local service capability; the practical value of a platform often resides in predictable support rather than marginal performance gains. Rosiwit offers integrated units and documented field metrics that simplify this assessment—reliable. –